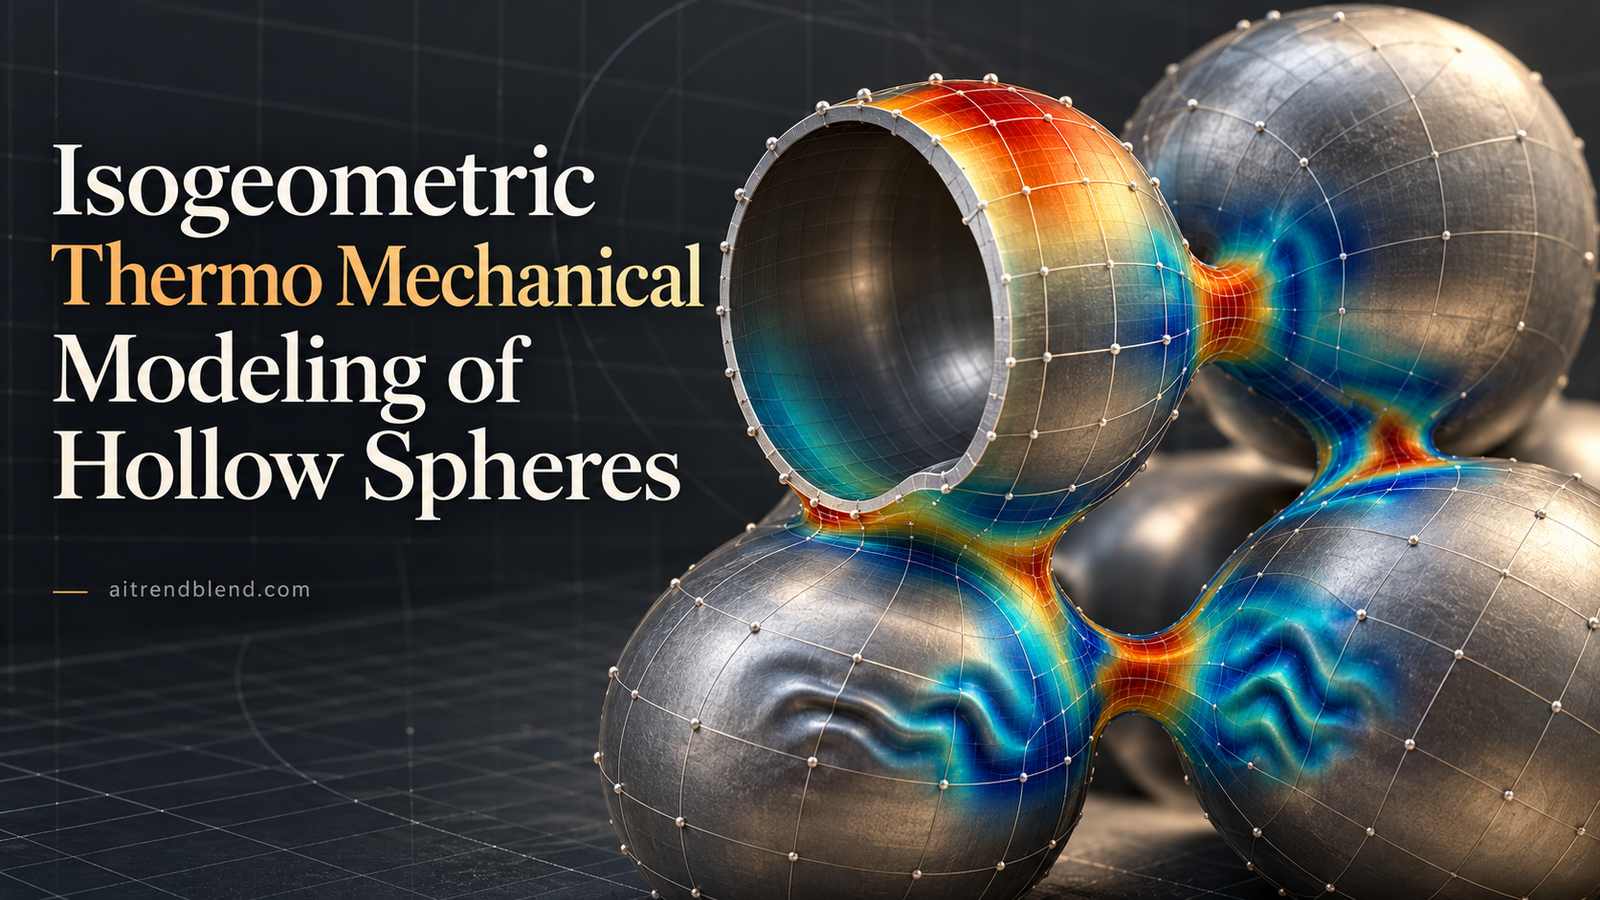
Inside aerospace heat shields, acoustic dampers, and powder-metallurgy steel foams, thousands of thin-walled hollow spheres fuse together at microscopic sinter necks to deliver a rare combination of ultra-low mass, high structural compliance, and thermal insulation. Modeling how those curved shells stretch, bend, kink, or wrinkle when subjected to simultaneous thermal shocks and mechanical loads is a notorious computational bottleneck. Standard three-dimensional finite element meshes require hundreds of thousands of volumetric elements just to resolve a single thin wall and cannot naturally evaluate second spatial derivatives across element borders. T. Wiegold, P. Kurzeja, S. Klinge, and J. Mosler at TU Dortmund University and Technische Universität Berlin solved this challenge by uniting higher-gradient continuum mechanics with NURBS-based Isogeometric Analysis (IGA), matching full 3D Abaqus simulations within 1.3 percent while using 24 times fewer degrees of freedom.
Key Research Takeaways
- The authors derive a geometrically exact, thermo-mechanically coupled shell formulation from second-gradient continuum mechanics (\(\Psi(F, \mathbb{F}, \theta)\)) and prove its exact equivalence to classical Kirchhoff-Love shell theory (\(\Psi(a_{\alpha\beta}, b_{\alpha\beta}, \theta)\)) while retaining the ability to capture in-plane gradient elasticity.
- Using Non-Uniform Rational B-Splines (NURBS) as Bubnov-Galerkin basis functions provides exact spherical geometry representation and native \(C^1\)-continuity across element boundaries, enabling direct computation of the second surface gradient \(\mathbb{F} = \text{GRAD}_{S_0} \text{GRAD}_{S_0} x\).
- A pseudo-time early-stage sintering algorithm identifies NURBS control points inside an evolving contact radius \(r(t)\), projects them onto a flat sinter plane defined by three reference nodes, and eliminates dependent degrees of freedom via Gauss-Jordan elimination.
- Benchmark comparisons against 3D Abaqus simulations (second-order 10-node tetrahedral C3D10 elements) show that IGA converges at 13,000 degrees of freedom versus 314,000 in 3D FEM (a 24-fold reduction) and matches two-sphere tensile reaction forces within 1.3 percent.
- Parametric studies across spheroid aspect ratios (\(R_0/L_0\)) and sinter-to-sphere radius ratios (\(r_0/R_0 \in \{0.10, 0.15, 0.20\}\)) reveal a power-law scaling (\(R^2 > 0.96\)) governed by a transition from soft wall bending to stiff membrane stretching.
Why Thin Sintered Hollow Spheres Challenge Standard Finite Element Solvers
The problem runs deeper than it first appears. Metallic and ceramic hollow sphere structures—fabricated via powder metallurgy or syntactic foam embedding—owe their mechanical and thermal properties to two distinct types of surface area: the free curved shell walls and the sintered planar contact necks where neighboring spheres fuse together. Because the wall thickness \(s\) is typically one-fiftieth to one-hundredth of the sphere radius \(R_0\), these shells can undergo large elastic rotations, snap-through kinking, and periodic wrinkling long before bulk materials would fracture.
Yet that exact slenderness makes numerical simulation painfully expensive. If you discretize two sintered hollow spheres using conventional 3D continuum finite elements (such as 10-node quadratic tetrahedra), avoiding aspect-ratio locking across a \(0.1\text{ mm}\) wall requires hundreds of thousands of degrees of freedom. Worse, if you switch to classical 2D Lagrange shell elements, standard polynomial shape functions only provide \(C^0\)-continuity across element edges. Because shell bending energy depends on surface curvature—which requires second spatial derivatives of the deformed position vector \(x\)—standard \(C^0\) finite elements cannot evaluate curvature jumps across element boundaries without resorting to rotational degrees of freedom (Reissner-Mindlin formulations) or mixed interpolation tricks.
Introduced by Hughes, Cottrell, and Bazilevs in 2005, Isogeometric Analysis (IGA) eliminates this geometric and continuity mismatch by adopting Non-Uniform Rational B-Splines (NURBS) directly from Computer Aided Design (CAD) as finite element shape functions. Because NURBS patches of polynomial degree \(p\) with knot multiplicity \(m\) naturally provide \(C^{p-m}\) inter-element continuity, quadratic (\(p=2\)) and cubic (\(p=3\)) NURBS basis functions deliver smooth \(C^1\) and \(C^2\) first and second derivatives everywhere across a curved manifold. For readers following our coverage in the Engineering AI and computational mechanics hub, IGA represents one of the cleanest bridges between exact CAD geometry and physics-based partial differential equation solvers.
Bridging Classical Shell Theory and Higher-Gradient Continuum Mechanics
In the literature, thin shells are typically derived along one of two separate tracks that rarely speak the same mathematical language. Structural engineers favor classical Kirchhoff-Love or Koiter shell theories expressed in terms of the first and second fundamental forms of differential geometry—namely the covariant surface metric tensor \(a_{\alpha\beta}\) (capturing membrane stretching) and the curvature tensor \(b_{\alpha\beta}\) (capturing bending). Continuum mechanicians working on size-dependent metamaterials and energetic interfaces, such as Javili, Dell’Isola, and Steinmann, prefer higher-gradient continuum mechanics formulated via the superficial deformation gradient \(F\) and its surface gradient \(\mathbb{F}\).
In their Computer Methods in Applied Mechanics and Engineering paper, Wiegold, Kurzeja, Klinge, and Mosler unify both formalisms on a two-dimensional curvilinear manifold \(\xi^\alpha\) (\(\alpha = 1, 2\)) embedded in 3D Euclidean space. Let \(X(\xi^\alpha) \in \mathcal{S}_0\) denote a material point on the undeformed reference shell surface and \(x(\xi^\alpha) \in \mathcal{S}\) denote its deformed counterpart. Taking partial derivatives with respect to \(\xi^\alpha\) yields the covariant tangent vectors, contravariant dual basis vectors, and unit surface normals \(N\) and \(n\) (Equations 3, 4, and 5).
From the second partial derivatives \(A_{\alpha,\beta} = X_{,\alpha\beta}\) and \(a_{\alpha,\beta} = x_{,\alpha\beta}\), the reference and deformed second-order curvature tensors \(B\) and \(b\) are defined in Equation 6, while the superficial deformation gradient \(F\) and second gradient \(\mathbb{F}\) follow Equations 9 and 10.
Here is where the theoretical connection becomes crystal clear. To guarantee frame-indifference (observer invariance under rigid-body rotations), a higher-gradient Helmholtz free energy \(\Psi(F, \mathbb{F})\) must depend on the right Cauchy-Green surface tensors \(C = F^T \cdot F\), \(\mathcal{C} = F^T \cdot \mathbb{F}\), and \(\mathbb{C} = \mathbb{F}^T : \mathbb{F}\) (Equations 13–16). Using the identity \(b_{\alpha\beta} = n \cdot \mathbb{F} : [A_\alpha \otimes A_\beta]\) from Equation 11, any classical shell energy \(\Psi(a_{\alpha\beta}, b_{\alpha\beta})\) is automatically a subset of the higher-gradient energy \(\Psi(F, \mathbb{F})\). However, the higher-gradient formulation is strictly more general because it can also include in-plane second-gradient terms such as \(a_{\alpha,\beta} \cdot a_{\gamma,\delta}\) that classical Kirchhoff-Love shell theory omits.
By comparing the virtual work of classical shell theory (\(\frac{1}{2}\delta a_{\alpha\beta}\tau^{\alpha\beta} + \delta b_{\alpha\beta}M^{\alpha\beta}\)) against the higher-gradient weak form (\(P : \delta F + \mathbb{P} \therefore \delta\mathbb{F}\)), the authors derive the exact closed-form mapping (Equation 31) between classical Kirchhoff stresses \(\tau^{\alpha\beta}\) and bending moments \(M^{\alpha\beta}\) and the generalized Piola-Kirchhoff stress tensors \(P = P^{(1)} + P^{(2)}\) and hyperstress \(\mathbb{P}\).
Coupled Thermo-Hyperelasticity and the First Law of Thermodynamics
When a thin metallic hollow sphere is heated at its equator or cooled at its poles, mechanical stretching and bending couple directly to heat conduction and thermo-elastic expansion. Applying the first law of thermodynamics to the 2D shell manifold \(\mathcal{S}_0\) with superficial tangential heat flux \(J = J^\alpha A_\alpha = -k\,\text{GRAD}_{S_0}\theta\) (Fourier law with thermal conductivity \(k\), Equation 50) and Legendre transform \(\Psi = u – \theta\mathcal{N}\) yields the coupled temperature evolution equation in strong form (Equation 35) and weak form (Equation 36).
In Equation 35, the third term represents heat storage via specific heat capacity \(c_d = \theta \frac{\partial^2 \Psi}{\partial \theta^2}\), while the fourth term \(\frac{\partial^2 \Psi}{\partial \theta \partial F} : \dot{F}\theta\) captures structural Gough-Joule heating and cooling induced by rapid membrane strain rates \(\dot{F}\) (the fifth higher-order bending-heating term is neglected). To instantiate this framework, the authors define the surface Green-Lagrange strain tensor \(E\) and the relative curvature tensor \(K\) in Equation 39:
Combining a plane-stress Saint-Venant-Kirchhoff mechanical energy \(\Psi^m = \Psi^m_{mem} + \Psi^m_{ben}\) (with thickness-scaled 2D Lamé parameters \(\lambda = s \frac{2\tilde{\lambda}\tilde{\mu}}{\tilde{\lambda} + 2\tilde{\mu}}\) and \(\mu = s\tilde{\mu}\), and flexural stiffness tensor \(\mathbb{D} = \frac{s^2}{12}\mathbb{C}\)), a plane-stress thermo-mechanical coupling energy \(\Psi^c\), and a logarithmic thermal energy \(\Psi^\theta\) yields the complete prototype Helmholtz free energy and constitutive stress laws in Equations 45, 53, 54, and 55.
NURBS Isogeometric Implementation and Early-Stage Sintering Constraints
To discretize the coupled weak forms (Equations 51 and 52) without auxiliary rotational degrees of freedom, the authors employ a Bubnov-Galerkin isoparametric scheme using bivariate NURBS basis functions \(R_{i,j}(\xi, \eta)\) built from recursive Cox-de Boor B-splines \(N_{i,p}(\xi)\) and \(M_{j,q}(\eta)\) with control-point weights \(w_{i,j}\) (Equations 61 and 62).
Each eighth-sphere patch is discretized using quadratic NURBS elements, and time derivatives are integrated via implicit first-order backward Euler differences \(\dot{(\bullet)} = \frac{\bullet_{n+1} – \bullet_n}{\Delta t}\) with \(\Delta t = 0.1\text{ s}\) (Equation 60). This physics-preserving discretization philosophy complements the surface and contour modeling approaches we explored in TEAMS Mamba Snake and physics-guided ultrasound simulation.
Modeling Early-Stage Sintering Neck Growth via Linear Master-Slave Constraints
How do you form a flat sintered contact neck of radius \(r_0\) between two curved hollow spheres while preserving smooth \(C^1\) shell walls? Physically, early-stage sintering is driven by surface, grain-boundary, and volume diffusion following the generalized power law of Pino-Muñoz et al. in Equation 63:
Numerically, before any external service loads are applied, the solver steps through a pseudo-time sintering phase until \(r(t)\) reaches the target sinter neck radius \(r_0\). At each step, all NURBS control points lying inside \(r(t)\) are translated along the inter-sphere normal \(n_c\) into the flat contact plane via \(\Delta x_{offset}\) (Equation 65). Three primary control points \(x_1, x_2, x_3\) span the sinter plane, and every other interior control point \(x_a\) is linked to them via barycentric scaling factors \(f_1, f_2\) (Equation 64) so points can relax tangentially during neck formation without residual pre-stress. All linear multi-point constraints (\(C^1\) patch symmetry plus sinter-plane coupling) are assembled and eliminated from the global stiffness matrix via Gauss-Jordan elimination following Webb (1990).
Benchmark Validation Against Analytical Plates and 3D Abaqus FEM
Before exploring complex thermal buckling, the authors validated their IGA solver across four rigorous mechanical benchmarks using the material properties in Table 1 of the paper: bulk Young’s modulus \(E = 1.2 \times 10^6\text{ kg m}^{-1}\text{s}^{-2}\) (1.2 MPa), Poisson’s ratio \(\nu = 0.3\), wall thickness \(s = 0.1\text{ mm}\), 2D Lamé parameters \(\lambda = 39.6\text{ kg s}^{-2}\) and \(\mu = 46.2\text{ kg s}^{-2}\), thermal conductivity \(k = 1\text{ kg m K}^{-1}\text{s}^{-3}\), heat capacity \(c_d = 0.01\text{ J K}^{-1}\), thermal expansion coefficient \(\alpha = 6 \times 10^{-3}\text{ K}^{-1}\), and thermo-mechanical coupling constants \(c_1 = 1.03\text{ kg s}^{-2}\text{K}^{-1}\) and \(c_2 = 0.01\text{ kg s}^{-2}\text{K}^{-2}\).
| Benchmark Problem | Discretization / Method | Degrees of Freedom (DOFs) ↓ | Relative Error / Deviation vs. Reference ↓ | Key Computational Finding |
|---|---|---|---|---|
| Square Plate (\(a=b=12\text{ mm}\), Sinusoidal Load) | IGA Quadratic (\(p=2\)), \(3 \times 3\) mesh | Ultra-coarse | \(\approx 3.0\%\) vs. Analytical (Ugural) | Rapid convergence even on 9 elements |
| Square Plate (\(a=b=12\text{ mm}\), Sinusoidal Load) | IGA Quadratic (\(p=2\)), \(6 \times 6\) / Cubic \(3 \times 3\) | Coarse | \(< 1.0\%\) vs. Analytical | Cubic splines hit sub-1% on \(3 \times 3\) grid |
| Square Plate (\(a=b=12\text{ mm}\), Sinusoidal Load) | IGA NURBS, \(10 \times 10\) mesh | Standard | \(< 0.12\%\) vs. Analytical | Exact flexural rigidity \(D \approx 2465.58\text{ N mm}\) |
| Simply Supported Plate (Uniform Pressure) | Abaqus 3D FEM (10-node C3D10 tetrahedra) | 314,000 DOFs | \(< 2.0\%\) vs. Analytical | Requires 24× more DOFs than IGA |
| Simply Supported Plate (Uniform Pressure) | Proposed IGA Shell Framework | 13,000 DOFs | \(< 2.0\%\) vs. Analytical | 24× DOF reduction compared to 3D Abaqus |
| Two Sintered Spheres Tension (\(R_0=5\text{ mm}, r_0=2\text{ mm}\)) | IGA (\(50 \times 50\)) vs. Abaqus 3D (113k C3D10 elements) | \(\sim 10^4\) vs. \(> 3 \times 10^5\) | \(1.3\%\) (Finest) / \(3.2\%\) (\(35 \times 35\) mesh) | Matches 3D reaction force \(F_{reac} \approx 0.54\text{ N}\) at \(u=0.05\text{ mm}\) |
Look at the efficiency gap in Table 1 above. To reach convergence on a simply supported plate, full 3D Abaqus simulations using quadratic 10-node C3D10 tetrahedra require 314,000 degrees of freedom, whereas the NURBS IGA shell model converges at just 13,000 degrees of freedom—a 24-fold reduction in system size. On the tensile test of two sintered hollow spheres (\(R_0 = 5\text{ mm}\), sinter radius \(r_0 = 2\text{ mm}\), pulled by \(0.05\text{ mm}\)), the \(35 \times 35\) IGA mesh agrees with a 113,000-element 3D Abaqus model within 3.2 percent, narrowing to 1.3 percent at \(50 \times 50\) elements.
“Both the proposed IGA framework as well as the three-dimensional simulations perform very well with deviations below 2%. More importantly and as anticipated, the fully three-dimensional simulation requires 24 times more degrees of freedom until convergence (314k vs 13k).”
T. Wiegold, P. Kurzeja, S. Klinge, and J. Mosler, Computer Methods in Applied Mechanics and Engineering (2025)
Thermo-Mechanical Buckling, Wrinkling, and Scaling Laws in Sintered Spheroids
With the numerical framework verified, the authors investigated two rich physical systems: a single hollow sphere (\(s_0/R_0 = 1/100\), \(34 \times 34\) quadratic NURBS elements per eighth-sphere) subjected to six combinations of transient equatorial heating (\(323\text{ K}\)) and localized point or ring cooling (\(273\text{ K}\)), and a pair of sintered hollow spheroids (\(s_0/R_0 = 1/50\)) across varying radii, sinter necks, and aspect ratios.
On the single hollow sphere, post-processing the through-thickness strain invariant \(J_2^E\) across the inner, middle, and outer shell surfaces (\(\xi^3 \in [-s/2, s/2]\), Equations 68–71) reveals how mechanical confinement transforms thermal contraction into geometric instability:
- Four-Point Cooling (Free vs. Fixed): Cooling four isolated points while heating the equator flattens the sphere locally. Fixing those four cooled points in \(z\) or in all \((x, y, z)\) directions counteracts thermal contraction, generating sharp local kinks and reaction force peaks from \(-8.3\text{ MPa}\) to \(+2.4\text{ MPa}\).
- Circumferential Ring Cooling (Ton-Like Flattening vs. Wrinkling Buckling): Cooling two parallel latitude rings turns the sphere into an oblate spheroid; fixing the rings vertically in \(z\) pulls the top and bottom poles into completely flat caps (“ton-like” barrel geometry) with reaction forces of \(1.9\text{ MPa}\). When those two cooled rings are fixed in all \((x, y, z)\) directions, compressive thermal stresses build until the reaction forces suddenly drop and the shell undergoes bifurcated wrinkling buckling, doubling the maximum strain invariant \(J_2^E\) from \(0.16\) to \(0.30\) with peak reaction forces of \(16.8\text{ MPa}\).
Decoupling Stiffness and Density in Sintered Spheroid Pairs
In Section 5.2, the authors analyzed two sintered hollow spheroids as a Representative Volume Element (RVE) for periodic metallic foams, sweeping initial sphere radius \(R_0 \in \{2.5, 5.0, 7.5\}\text{ mm}\), normalized sinter contact radius \(r_0/R_0 \in \{0.10, 0.15, 0.20\}\), and spheroid aspect ratio \(R_0/L_0 \in [1/8, 4]\). Across the intermediate aspect-ratio regime \(1/4 \le R_0/L_0 \le 2/1\), the dimensionless initial tensile stiffness follows a remarkably clean power law on a log-log scale, as documented in Table 2 of the paper:
| Initial Sphere Radius \(R_0\) | Log-Log Slope (\(R^2\)) at \(r_0/R_0 = 0.10\) | Log-Log Slope (\(R^2\)) at \(r_0/R_0 = 0.15\) | Log-Log Slope (\(R^2\)) at \(r_0/R_0 = 0.20\) | Dominant Physical Mechanism |
|---|---|---|---|---|
| \(R_0 = 2.5\text{ mm}\) (Highest Package Density) | \(2.4202 \times 10^{-5}\) (\(0.9935\)) | \(3.0640 \times 10^{-5}\) (\(0.9895\)) | \(4.0859 \times 10^{-5}\) (\(0.9856\)) | Strongest stiffness gain with neck growth |
| \(R_0 = 5.0\text{ mm}\) (Intermediate Density) | \(1.8197 \times 10^{-5}\) (\(0.9776\)) | \(2.4479 \times 10^{-5}\) (\(0.9712\)) | \(3.4573 \times 10^{-5}\) (\(0.9677\)) | Balanced bending-to-stretching transition |
| \(R_0 = 7.5\text{ mm}\) (Lowest Package Density) | \(1.6061 \times 10^{-5}\) (\(0.9671\)) | \(2.2256 \times 10^{-5}\) (\(0.9611\)) | \(3.2017 \times 10^{-5}\) (\(0.9607\)) | Ultra-lightweight RVE (\(R^2 > 96\%\) across all) |
Two actionable design rules emerge from Figure 7 and Table 2. First, the sphere radius \(R_0\) controls the dimensionless package density \((m^{\text{RVE}}/V^{\text{RVE}})/\rho^{\text{material}}\), whereas the sinter ratio \(r_0/R_0\) controls the initial tensile stiffness at nearly constant mass. Therefore, increasing the sinter neck ratio to \(r_0/R_0 = 0.20\) is the most effective way to build high-stiffness, ultra-lightweight foams. Second, elongating the spheres along the load axis (increasing \(R_0/L_0\)) shifts the deformation mode from compliant wall bending (\(\Psi^m_{ben}\)) to stiff in-plane membrane stretching (\(\Psi^m_{mem}\)), increasing stiffness by nearly an order of magnitude before saturating at \(R_0/L_0 \approx 4\).
Finally, when a sintered pair (\(r_0/R_0 = 0.5/5\), \(s_0/R_0 = 0.1/5\)) is heated by \(\Delta\theta = +5\text{ K}\) on the left bisector while held at \(273\text{ K}\) on the right (Figure 9), the normalized stress invariant \(J_2^S/E^2\) remains benign (\(\sim 10^{-14}\)) under free expansion, intensifies sharply around the sinter neck under fixed horizontal confinement, and spikes by two orders of magnitude to \(10^{-12}\) when longitudinal pre-stretching is combined with heating—pinpointing the sinter neck perimeter as the primary locus of plastic yielding or thermal fatigue.
Because NURBS basis functions are analytically differentiable to second order and reduce shell degrees of freedom by \(24\times\), the energy functional in Equation 53 can serve directly as a physics-informed loss function for neural operators or differentiable metamaterial inverse design—similar to the hybrid physics-ML paradigms we cover in graph-based spatial modeling and parameter-efficient foundation adaptation.
Honest Limitations and Open Challenges
In Sections 4.4, 4.5, 5.2, and 6, the authors candidly highlight four methodological and physical limitations of the current framework:
- Non-Monotonic Mesh Convergence at Coarse Sinter Discretizations: Because control points are snapped discretely into the sinter plane as elements fall inside \(r_0\) and smoothed by \(C^1\) splines, force convergence oscillates on coarse meshes (\(10 \times 10\) to \(25 \times 25\)) before stabilizing at \(30 \times 30\) to \(40 \times 40\) elements.
- Competing Resolution Demands Between Sinter Neck and Spheroid Aspect Ratio: When \(r_0/L_0 \ll 1\) in strongly elongated spheroids, resolving the tiny sinter neck curvature (\(\approx 1/r_0\)) with a uniform structured NURBS patch forces an unnecessarily fine mesh across the long, flat sides of the spheroid. Implementing local hierarchical NURBS refinement (such as T-splines or THB-splines) is needed to avoid over-meshing.
- Assumption of Smooth \(C^1\) Early-Stage Necking and Purely Elastic Material Law: The model assumes early-stage sintering with constant wall thickness \(s\) and a smooth \(C^1\) transition into a flat contact disk. Late-stage bulk sintering often produces sharp \(C^0\) dihedral kinks, and the high stress concentrations (\(J_2^S/E^2 \sim 10^{-12}\)) observed at the sinter neck under combined tension and heating indicate that irreversible \(J_2\) elasto-plasticity or visco-plasticity must be incorporated in future work.
- Polar Coordinate Apex Singularity: Parameterizing a sphere with standard latitude-longitude curvilinear coordinates \(\xi^1, \xi^2\) causes \(\xi^2\) tangent vectors to collapse at the top pole, requiring numerical integration points to be evaluated slightly away from the singular apex.
Conclusion and Future Directions
Wiegold, Kurzeja, Klinge, and Mosler have established a rigorous, computationally lean foundation for simulating nonlinear thermo-elastic shells with sintered contacts. By deriving the governing equations from second-gradient continuum mechanics and proving their exact stress-and-moment correspondence with classical Kirchhoff-Love shell theory, their formulation accommodates both standard membrane-bending mechanics and higher-gradient surface elasticity within a unified variational principle.
Implementing that variational principle with \(C^1\)-continuous NURBS patches inside an Isogeometric Analysis framework pays immediate dividends. Where a 3D tetrahedral finite element model needs 314,000 degrees of freedom to avoid locking, the IGA shell formulation converges in 13,000 degrees of freedom, accurately predicting localized thermal kinking, barrel flattening, and multi-wave wrinkling instabilities on thin hollow spheres.
For materials engineers designing metallic hollow sphere foams or thermal insulators, the two-spheroid RVE study provides a clear quantitative roadmap: use the sphere radius \(R_0\) to dial in target foam density, maximize the sinter neck ratio \(r_0/R_0\) to boost tensile stiffness without adding mass, and orient elongated prolate spheroids (\(R_0/L_0 > 1\)) along the primary load path to exploit membrane stretching over wall bending.
Future research combining local adaptive spline refinement around the sinter neck, \(C^0\) kinked contact transitions for late-stage sintering, and coupled elasto-plastic damage models will further expand this framework—and provide high-fidelity training data for surrogate AI metamaterial design.
Complete PyTorch Implementation of Differentiable NURBS Thermo-Elastic Shells
Below is a complete, self-contained, runnable PyTorch implementation of the core mathematical building blocks from Sections 2, 3, and 4 of the paper, including recursive Cox-de Boor B-spline and bivariate NURBS surface evaluation (Equations 61 and 62), automatic differentiation of first and second surface gradients (\(A_\alpha, a_\alpha, N, n, B_{\alpha\beta}, b_{\alpha\beta}, F, \mathbb{F}\) in Equations 3–10), the surface Green-Lagrange strain \(E\) and relative curvature \(K\) (Equation 39), the coupled plane-stress Saint-Venant-Kirchhoff thermo-hyperelastic Helmholtz energy \(\Psi(E, K, \theta)\) and stress tensors \(\tau^{\alpha\beta}, M^{\alpha\beta}, P, \mathbb{P}\) (Equations 31, 43, 45, 53–55), through-thickness strain invariant \(J_2^E\) post-processing (Equations 68–71), and a runnable smoke test optimizing a heated hemispherical shell patch.
import torch
import torch.nn as nn

# =====================================================================
# 1. RECURSIVE COX-DE BOOR B-SPLINES & BIVARIATE NURBS (EQS. 61 & 62)
# =====================================================================

def cox_de_boor_basis(xi: torch.Tensor, knots: torch.Tensor, degree: int) -> torch.Tensor:
    """
    Implements Equation (62):
    Differentiable recursive evaluation of 1D B-Spline basis functions N_{i,p}(xi)
    for evaluation coordinates xi [M] given knot vector [K] and polynomial degree p.
    """
    num_ctrl = len(knots) - degree - 1
    M = xi.shape[0]
    N = torch.zeros((M, len(knots) - 1), dtype=xi.dtype, device=xi.device)

    # Degree p = 0 base case
    for i in range(len(knots) - 1):
        if i == len(knots) - degree - 2:
            cond = (xi >= knots[i]) & (xi <= knots[i + 1])
        else:
            cond = (xi >= knots[i]) & (xi < knots[i + 1])
        N[:, i] = torch.where(cond, 1.0, 0.0)

    # Recursive elevation to degree p
    for p in range(1, degree + 1):
        N_next = torch.zeros((M, len(knots) - p - 1), dtype=xi.dtype, device=xi.device)
        for i in range(N_next.shape[1]):
            denom1 = knots[i + p] - knots[i]
            term1 = ((xi - knots[i]) / denom1) * N[:, i] if denom1 > 1e-8 else 0.0

            denom2 = knots[i + p + 1] - knots[i + 1]
            term2 = ((knots[i + p + 1] - xi) / denom2) * N[:, i + 1] if denom2 > 1e-8 else 0.0

            N_next[:, i] = term1 + term2
        N = N_next

    return N[:, :num_ctrl]


def evaluate_nurbs_patch(
    xi_grid: torch.Tensor,
    eta_grid: torch.Tensor,
    ctrl_pts: torch.Tensor,
    weights: torch.Tensor,
    knots_xi: torch.Tensor,
    knots_eta: torch.Tensor,
    degree: int = 2
) -> torch.Tensor:
    """
    Implements Equation (61):
    Evaluates bivariate NURBS surface X(xi, eta) or x(xi, eta) and temperature theta(xi, eta).
    ctrl_pts: [N_u, N_v, D], weights: [N_u, N_v].
    """
    N_xi = cox_de_boor_basis(xi_grid, knots_xi, degree)    # [M, N_u]
    M_eta = cox_de_boor_basis(eta_grid, knots_eta, degree) # [M, N_v]

    # Tensor product w_{i,j} N_i(xi) M_j(eta) -> [M, N_u, N_v]
    numer = torch.einsum('mi,mj,ij->mij', N_xi, M_eta, weights)
    denom = numer.sum(dim=(-2, -1), keepdim=True).clamp(min=1e-12)
    R = numer / denom  # Eq. (61): Rational basis [M, N_u, N_v]

    return torch.einsum('mij,ijd->md', R, ctrl_pts)


# =====================================================================
# 2. SHELL DIFFERENTIAL GEOMETRY & HIGHER-GRADIENT KINEMATICS (SEC. 2)
# =====================================================================

def compute_surface_kinematics(pos_fn, xi: torch.Tensor, eta: torch.Tensor):
    """
    Computes exact first and second covariant tangent vectors (Eqs. 3, 7),
    contravariant duals (Eq. 4), surface unit normal (Eq. 5), metric tensor,
    and curvature tensor components (Eq. 6) using C^1 autodiff.
    """
    xi = xi.clone().detach().requires_grad_(True)
    eta = eta.clone().detach().requires_grad_(True)
    pos = pos_fn(xi, eta)  # [M, 3]

    # First partial derivatives: g_1 = d(pos)/d(xi), g_2 = d(pos)/d(eta) (Eq. 3)
    g1, g2, g11, g12, g22 = [], [], [], [], []
    for d in range(3):
        grad_d = torch.autograd.grad(pos[:, d].sum(), (xi, eta), create_graph=True)
        g1.append(grad_d[0])
        g2.append(grad_d[1])

        # Second partial derivatives for curvature tensor (Eq. 7)
        g11_d = torch.autograd.grad(grad_d[0].sum(), xi, create_graph=True)[0]
        g12_d = torch.autograd.grad(grad_d[0].sum(), eta, create_graph=True)[0]
        g22_d = torch.autograd.grad(grad_d[1].sum(), eta, create_graph=True)[0]
        g11.append(g11_d)
        g12.append(g12_d)
        g22.append(g22_d)

    a1 = torch.stack(g1, dim=-1)    # [M, 3]
    a2 = torch.stack(g2, dim=-1)    # [M, 3]
    a11 = torch.stack(g11, dim=-1)  # [M, 3]
    a12 = torch.stack(g12, dim=-1)  # [M, 3]
    a22 = torch.stack(g22, dim=-1)  # [M, 3]

    # Covariant metric components a_{alpha, beta} = a_alpha . a_beta
    m11 = (a1 * a1).sum(dim=-1)
    m12 = (a1 * a2).sum(dim=-1)
    m22 = (a2 * a2).sum(dim=-1)
    metric_cov = torch.stack([torch.stack([m11, m12], dim=-1),
                              torch.stack([m12, m22], dim=-1)], dim=-2)  # [M, 2, 2]
    metric_contra = torch.linalg.inv(metric_cov)

    # Unit normal vector n = (a1 x a2) / ||a1 x a2|| (Eq. 5)
    cross = torch.linalg.cross(a1, a2, dim=-1)
    area_elem = torch.linalg.norm(cross, dim=-1, keepdim=True).clamp(min=1e-12)
    normal = cross / area_elem

    # Covariant curvature components b_{alpha, beta} = n . a_{alpha, beta} (Eq. 6)
    b11 = (normal * a11).sum(dim=-1)
    b12 = (normal * a12).sum(dim=-1)
    b22 = (normal * a22).sum(dim=-1)
    curv_cov = torch.stack([torch.stack([b11, b12], dim=-1),
                            torch.stack([b12, b22], dim=-1)], dim=-2)  # [M, 2, 2]

    return {
        "a1": a1, "a2": a2, "normal": normal,
        "metric_cov": metric_cov, "metric_contra": metric_contra,
        "curv_cov": curv_cov, "dA": area_elem.squeeze(-1)
    }


# =====================================================================
# 3. THERMO-HYPERELASTIC CONSTITUTIVE MODEL (SECTION 3 & TABLE 1)
# =====================================================================

class ThermoHyperelasticShellModel(nn.Module):
    """
    Implements Section 3 (Eqs. 39 - 55) with Table 1 material parameters:
    Computes Helmholtz energy Psi(E, K, theta), Kirchhoff membrane stress tau^{ab},
    bending moment tensor M^{ab}, and through-thickness J2 strain invariant (Eq. 68).
    """
    def __init__(
        self,
        E_bulk: float = 1.2e6,
        nu: float = 0.3,
        thickness_s: float = 0.1e-3,
        alpha_th: float = 6.0e-3,
        c_d: float = 0.01,
        theta_e: float = 273.0
    ):
        super().__init__()
        self.s = thickness_s
        self.alpha = alpha_th
        self.c_d = c_d
        self.theta_e = theta_e

        # 3D Bulk Lame parameters tilde_lambda, tilde_mu
        lam_3d = E_bulk * nu / ((1.0 + nu) * (1.0 - 2.0 * nu))
        mu_3d = E_bulk / (2.0 * (1.0 + nu))

        # Plane-stress 2D Lame parameters (Eq. 43) & Thermo-coupling (Eq. 45)
        self.lam = thickness_s * (2.0 * lam_3d * mu_3d) / (lam_3d + 2.0 * mu_3d)
        self.mu = thickness_s * mu_3d
        self.c1 = thickness_s * (2.0 * mu_3d / (lam_3d + 2.0 * mu_3d)) * 3.0 * alpha_th * (lam_3d + (2.0 / 3.0) * mu_3d)
        self.c2 = thickness_s * (9.0 * (alpha_th ** 2) / (lam_3d + 2.0 * mu_3d)) * ((lam_3d + (2.0 / 3.0) * mu_3d) ** 2)

    def forward(self, ref_kin: dict, cur_kin: dict, theta: torch.Tensor):
        A_cov = ref_kin["metric_cov"]
        A_con = ref_kin["metric_contra"]
        B_cov = ref_kin["curv_cov"]

        a_cov = cur_kin["metric_cov"]
        b_cov = cur_kin["curv_cov"]

        # Equation (39): Surface Green-Lagrange strain E_{ab} and relative curvature K_{ab}
        E_cov = 0.5 * (a_cov - A_cov)
        K_cov = b_cov - B_cov

        # Contravariant components E^{ab} = A^{ac} E_{cd} A^{db}
        E_con = torch.einsum('mac,mcd,mdb->mab', A_con, E_cov, A_con)
        K_con = torch.einsum('mac,mcd,mdb->mab', A_con, K_cov, A_con)

        tr_E = torch.einsum('mab,mab->m', E_cov, A_con)
        tr_K = torch.einsum('mab,mab->m', K_cov, A_con)
        E_norm_sq = torch.einsum('mab,mab->m', E_cov, E_con)
        K_norm_sq = torch.einsum('mab,mab->m', K_cov, K_con)

        # Equation (41): Membrane and Bending Mechanical Energies
        psi_mem = 0.5 * (self.lam * (tr_E ** 2) + 2.0 * self.mu * E_norm_sq)
        bend_factor = (self.s ** 2) / 12.0
        psi_ben = 0.5 * bend_factor * (self.lam * (tr_K ** 2) + 2.0 * self.mu * K_norm_sq)

        # Equations (44) & (48): Coupling Energy Psi^c and Thermal Energy Psi^theta
        d_theta = theta - self.theta_e
        psi_c = -self.c1 * d_theta * tr_E - 0.5 * self.c2 * (d_theta ** 2)
        psi_th = self.c_d * d_theta - self.c_d * theta * torch.log(theta / self.theta_e)

        psi_total = psi_mem + psi_ben + psi_c + psi_th  # Eq. (53)

        # Equations (54) & (55): Stress tensor tau^{ab} and Moment tensor M^{ab}
        tau_con = (self.lam * tr_E - self.c1 * d_theta).unsqueeze(-1).unsqueeze(-1) * A_con + 2.0 * self.mu * E_con
        M_con = bend_factor * (self.lam * tr_K.unsqueeze(-1).unsqueeze(-1) * A_con + 2.0 * self.mu * K_con)

        # Equation (68): Through-thickness strain invariant J2^E at outer surface (xi^3 = +s/2)
        E_outer = E_cov - (0.5 * self.s) * K_cov
        E_outer_mixed = torch.einsum('mac,mcb->mab', E_outer, A_con)
        dev_E = E_outer_mixed - 0.5 * torch.einsum('maa->m', E_outer_mixed).unsqueeze(-1).unsqueeze(-1) * torch.eye(2, device=theta.device)
        j2_strain = 0.5 * torch.einsum('mab,mba->m', dev_E, dev_E)

        return psi_total, tau_con, M_con, j2_strain


# =====================================================================
# 4. SINTERING CONSTRAINT PROJECTION (EQS. 63 - 65) & SMOKE TEST
# =====================================================================

def apply_sinter_plane_constraints(ctrl_pts: torch.Tensor, r_sinter: float, z_plane: float = 0.0) -> torch.Tensor:
    """
    Implements Section 4.4 (Eqs. 64 & 65):
    Identifies control points within sinter contact radius r_sinter and projects
    their normal coordinate onto the flat sinter contact plane.
    """
    radial_dist = torch.sqrt(ctrl_pts[..., 0] ** 2 + ctrl_pts[..., 1] ** 2)
    in_sinter = radial_dist <= r_sinter
    projected = ctrl_pts.clone()
    projected[..., 2] = torch.where(in_sinter, torch.full_like(projected[..., 2], z_plane), projected[..., 2])
    return projected


if __name__ == "__main__":
    torch.manual_seed(42)
    device = torch.device("cuda" if torch.cuda.is_available() else "cpu")

    # 1. Construct Quadratic (p=2) 4x4 NURBS Patch for a Hollow Sphere Octant (R0 = 5.0 mm)
    degree = 2
    knots = torch.tensor([0.0, 0.0, 0.0, 0.5, 1.0, 1.0, 1.0], device=device)
    N_u, N_v = 4, 4
    R0 = 5.0e-3

    u_lin = torch.linspace(0.15, 1.4, N_u, device=device)
    v_lin = torch.linspace(0.15, 1.4, N_v, device=device)
    uu, vv = torch.meshgrid(u_lin, v_lin, indexing='ij')

    X_ctrl = torch.stack([
        R0 * torch.sin(uu) * torch.cos(vv),
        R0 * torch.sin(uu) * torch.sin(vv),
        R0 * torch.cos(uu)
    ], dim=-1)  # [4, 4, 3] Reference Control Points
    weights = torch.ones((N_u, N_v), device=device)

    # Apply early-stage sinter neck projection (r0/R0 = 0.20)
    X_ctrl_sintered = apply_sinter_plane_constraints(X_ctrl, r_sinter=0.20 * R0, z_plane=R0)

    # Learnable deformed control points x_e initialized from reference
    x_ctrl = nn.Parameter(X_ctrl_sintered.clone() + 1e-5 * torch.randn_like(X_ctrl_sintered))
    theta_ctrl = torch.full((N_u, N_v, 1), 310.0, device=device)  # Heated by +37 K

    # 2. Quadrature grid in parameter space P = [0.1, 0.9]^2
    q_pts = torch.linspace(0.1, 0.9, 6, device=device)
    xi_q, eta_q = torch.meshgrid(q_pts, q_pts, indexing='ij')
    xi_flat, eta_flat = xi_q.reshape(-1), eta_q.reshape(-1)

    ref_fn = lambda x_in, e_in: evaluate_nurbs_patch(x_in, e_in, X_ctrl_sintered, weights, knots, knots, degree)
    ref_kin = compute_surface_kinematics(ref_fn, xi_flat, eta_flat)

    # 3. Optimize Total Thermo-Hyperelastic Potential Energy I(x) (Eq. 20 & Eq. 53)
    material = ThermoHyperelasticShellModel().to(device)
    optimizer = torch.optim.Adam([x_ctrl], lr=1e-5)

    for step in range(5):
        optimizer.zero_grad()
        cur_fn = lambda x_in, e_in: evaluate_nurbs_patch(x_in, e_in, x_ctrl, weights, knots, knots, degree)
        cur_kin = compute_surface_kinematics(cur_fn, xi_flat, eta_flat)
        theta_q = evaluate_nurbs_patch(xi_flat, eta_flat, theta_ctrl, weights, knots, knots, degree).squeeze(-1)

        psi, tau_con, M_con, j2_e = material(ref_kin, cur_kin, theta_q)
        total_energy = torch.sum(psi * ref_kin["dA"].detach())
        total_energy.backward()
        optimizer.step()

    print(f"IGA Quadrature Points: {xi_flat.numel()} | Total Potential Energy: {total_energy.item():.6e} J")
    print(f"Max Outer-Surface Strain Invariant J2^E: {j2_e.max().item():.6e} | Stress Tensor Shape: {tuple(tau_con.shape)}")
Frequently Asked Questions
Why is Isogeometric Analysis well suited for modeling thin hollow sphere shells?
Isogeometric Analysis uses Non-Uniform Rational B-Splines (NURBS) directly from CAD as finite element shape functions. NURBS represent curved spherical surfaces and sintered contact necks with geometric exactness and naturally provide C1-continuity across element boundaries, allowing the direct calculation of the second spatial derivatives required for shell bending curvature without extra rotational degrees of freedom.
How does the higher-gradient continuum shell formulation relate to classical Kirchhoff-Love shell theory?
Classical Kirchhoff-Love shell theory defines energy in terms of the covariant surface metric tensor and the curvature tensor, whereas higher-gradient continuum mechanics uses the superficial deformation gradient F and its surface gradient. The authors prove that both formulations are mathematically equivalent when using standard stretching and bending measures, while the higher-gradient formulation is more general because it also captures in-plane gradient elasticity.
How many degrees of freedom does the IGA shell model save compared to 3D Abaqus finite element simulations?
On a benchmark simply supported plate under uniform pressure, both the proposed IGA shell framework and a 3D Abaqus simulation using 10-node quadratic C3D10 tetrahedral elements achieve deviations below 2 percent against the analytical solution, but the 3D Abaqus model requires 314,000 degrees of freedom compared to just 13,000 for IGA, representing a 24-fold reduction.
How is the sintering process between two hollow spheres implemented numerically?
Before applying mechanical or thermal loads, a pseudo-time sintering step grows the contact radius until the target sinter neck radius is reached. All NURBS control points inside that radius are translated into a flat sinter plane defined by three reference points, linked via barycentric linear constraints so they can relax in-plane without pre-stress, and coupled via Gauss-Jordan elimination.
How do sphere radius and sinter neck radius affect the density and stiffness of hollow sphere foams?
Parametric tensile studies on two sintered hollow spheres show that the initial sphere radius primarily controls the effective package density of the structure, whereas the ratio of sinter contact radius to sphere radius strongly governs the initial tensile stiffness. Increasing the sinter-to-sphere radius ratio allows engineers to maximize stiffness while keeping foam density low.
What causes wrinkling buckling in a single thermo-mechanically loaded hollow sphere?
When a hollow sphere is heated along its equator and subsequently cooled along two parallel circumferential rings whose displacements are fixed in all three spatial directions, the mechanical fixation prevents thermal contraction. This conflict triggers a structural instability marked by a sudden drop in reaction forces and the formation of periodic surface wrinkles with alternating inner and outer strain fields.
Explore the Published Study in Computer Methods in Applied Mechanics and Engineering
Read the complete peer-reviewed open-access paper, mathematical derivations, and parametric sintering studies by the TU Dortmund University and Technische Universität Berlin research team.
Academic Citation Wiegold, T., Kurzeja, P., Klinge, S., & Mosler, J. (2025). Non-linear thermo-mechanical modeling of hollow sphere shells using isogeometric analysis. Computer Methods in Applied Mechanics and Engineering, 446, 118227. https://doi.org/10.1016/j.cma.2025.118227
This analysis is based on the published paper and an independent evaluation of its claims.