Robotic AI

Artificial intelligence is no longer confined to digital screens—it is learning to move, interact, and operate in the physical world. This category explores the rapidly evolving field of Robotic AI 🤖. Dive into cutting-edge research on how machine learning, computer vision, and sensor fusion are empowering autonomous systems. From reinforcement learning in virtual simulations and advanced kinematics to the vision-language models driving modern humanoid robots, stay updated on the algorithms teaching machines to navigate and manipulate their environments safely and intelligently.

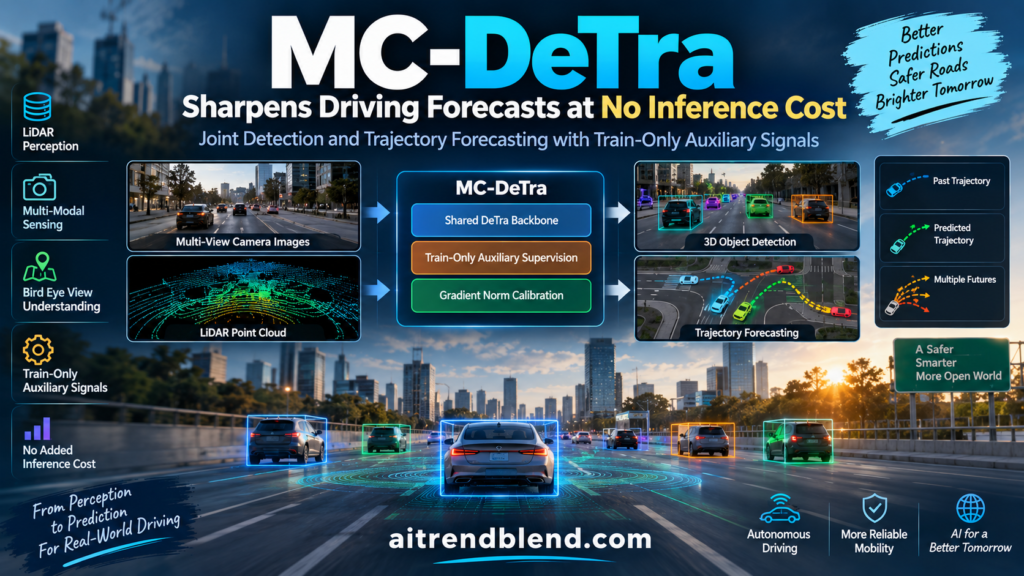
MC-DeTra Sharpens Driving Forecasts at No Inference Cost

MC-DeTra Sharpens Driving Forecasts at No Inference Cost

Analysis by the aitrendblend editorial team  •  Robotics and autonomous systems  •  Based on an arXiv preprint  •  September 2026 joint detection and forecasting trajectory forecasting autonomous driving bird eye view LiDAR perception auxiliary supervision MC-DeTra adds three training only signals that shape the shared bird eye view representation of a joint detector and forecaster, […]

MC-DeTra Sharpens Driving Forecasts at No Inference Cost Read More »
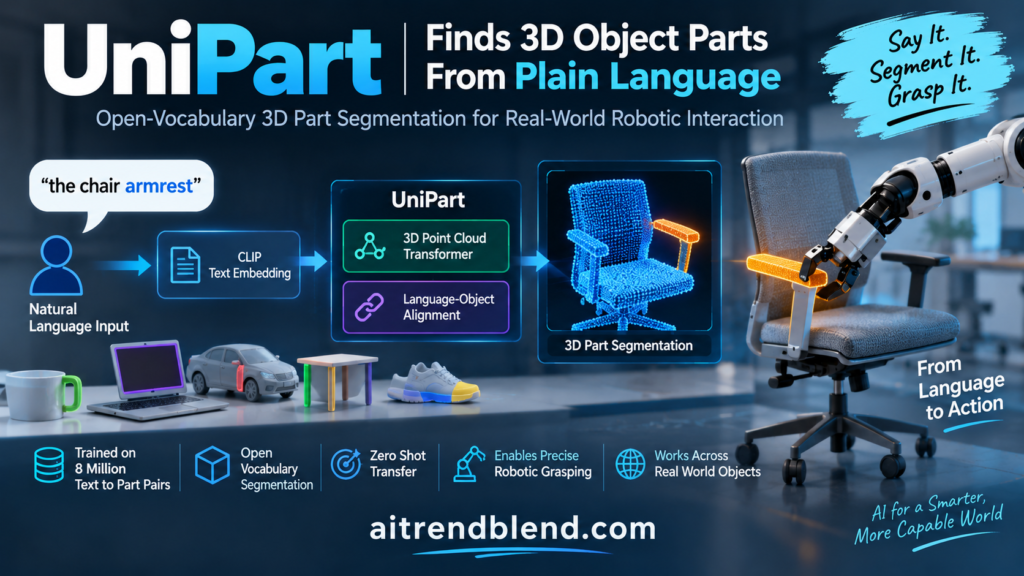
UniPart Finds 3D Object Parts From Plain Language

UniPart Finds 3D Object Parts From Plain Language

Analysis by the aitrendblend editorial team  •  Robotics and autonomous systems  •  Based on an arXiv preprint  •  September 2026 3D part segmentation language grounded segmentation zero shot transfer open vocabulary embodied interaction robotic grasping UniPart takes a point cloud and a phrase like handle of a drill, and returns a mask over exactly those

UniPart Finds 3D Object Parts From Plain Language Read More »

Why a Warehouse Robot Should Sometimes Take the Longer Path

Why a Warehouse Robot Should Sometimes Take the Longer Path

Analysis by the aitrendblend editorial team · Robotics and autonomous control · 14 min read Risk aware routing Markov decision process Stochastic shortest path Warehouse robotics An autonomous mobile robot at a decision point, weighing a shorter corridor against a wider one with better visibility. Picture a delivery robot in a warehouse aisle. It has

Why a Warehouse Robot Should Sometimes Take the Longer Path Read More »

How 1 Fascinating Robotized Crane Swings On Purpose to Boost Speed

How 1 Fascinating Robotized Crane Swings On Purpose to Boost Speed

Analysis by the aitrendblend editorial team. Source paper published in IEEE Transactions on Robotics, volume 42, 2026. Built and tested at KU Leuven, Belgium. Underactuated Robots Gantry Crane Pendulum Dynamics Passive Grasping Finite State Machine The crane swings the payload like a pendulum with a changing cable length, timing the release to slide it under

How 1 Fascinating Robotized Crane Swings On Purpose to Boost Speed Read More »

A Magnetic HUD System Guides Compression Anastomosis Surgery

A Magnetic HUD System Guides Compression Anastomosis Surgery

Analysis by the aitrendblend editorial team · Pillar 10, Robotics and autonomous control · Paper DOI 10.1109/TRO.2025.3631817 · Medical reviewer Surgical Robotics Magnetic Localization Head Up Display Endoscopic Surgery Six-DoF Tracking This article covers an experimental medical device and animal study, not a clinical treatment. The system described here has been tested in laboratory setups

A Magnetic HUD System Guides Compression Anastomosis Surgery Read More »

BeyondMimic Controls Humanoids With Guided Diffusion

BeyondMimic: The 1st Revolutionary Way Guided Diffusion Controls Humanoids

Analysis by the aitrendblend editorial team  ·  Robotics and autonomous systems  ·  Reading time about 16 minutes Humanoid Robots Guided Diffusion Motion Tracking Classifier Guidance Sim to Real Whole Body Control A humanoid robot throws an aerial cartwheel on forest ground. The same model can be steered to walk to a waypoint or dodge an

BeyondMimic: The 1st Revolutionary Way Guided Diffusion Controls Humanoids Read More »

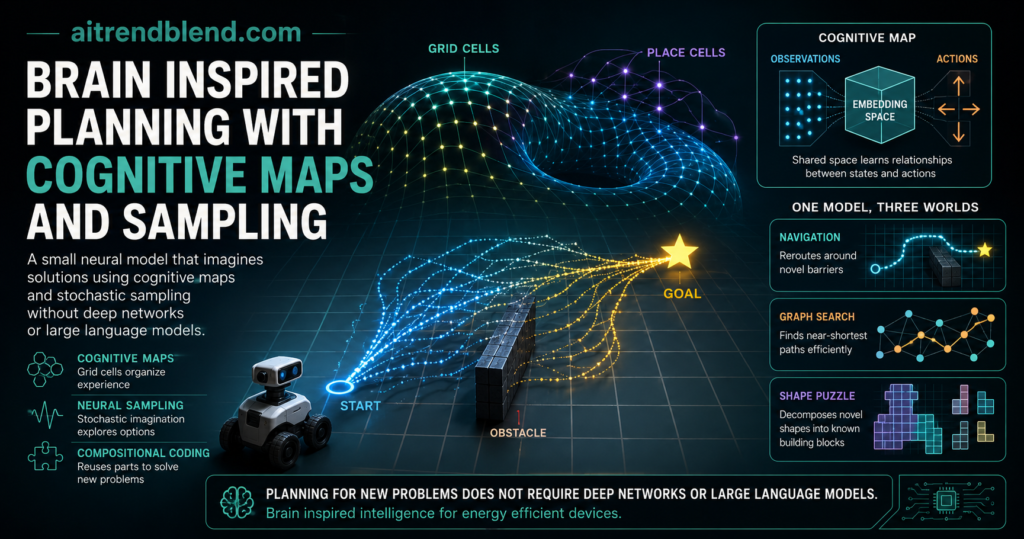
Brain Inspired Planning With Cognitive Maps and Sampling

Brain Inspired Planning With Cognitive Maps and Sampling

Analysis by the aitrendblend editorial team  ·  Robotics and autonomous systems  ·  Reading time about 16 minutes Cognitive Maps Neural Sampling Grid Cells Goal Directed Planning Neuromorphic Computing GCML A cognitive map built from grid cell activity lets a small neural model imagine a route to a goal, reroute around obstacles, and solve abstract puzzles,

Brain Inspired Planning With Cognitive Maps and Sampling Read More »

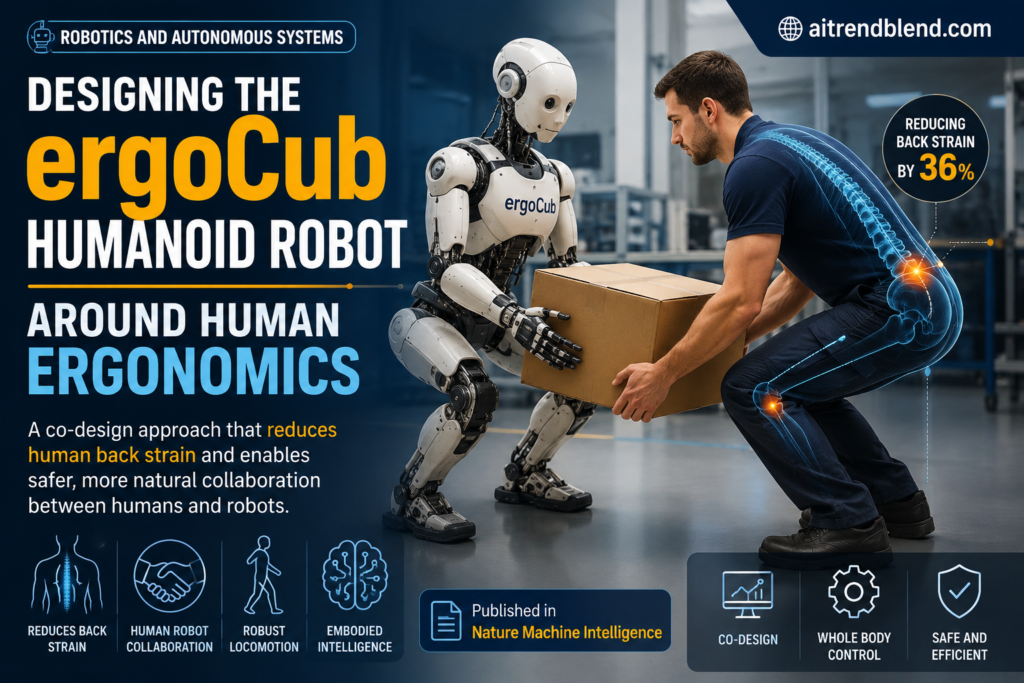
Designing the ergoCub Humanoid Around Human Ergonomics

Designing the ergoCub Humanoid Around Human Ergonomics

Analysis by the aitrendblend editorial team  ·  Robotics and autonomous systems  ·  Explains published research, not medical or safety advice  ·  Reading time about 18 minutes Humanoid Robot ergoCub Human Robot Collaboration Embodied Intelligence Robot Co Design Ergonomics ergoCub was shaped by an optimization that treats the human partner as part of the design, choosing

Designing the ergoCub Humanoid Around Human Ergonomics Read More »

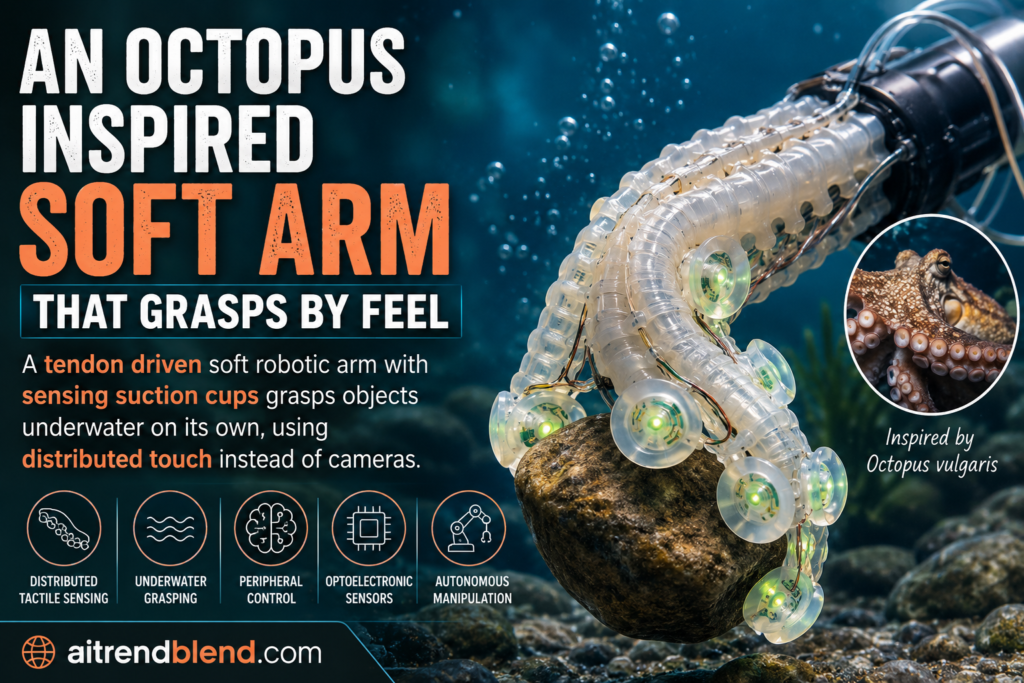
An Octopus Inspired Soft Arm That Grasps By Feel

An Octopus Inspired Soft Arm That Grasps By Feel

Analysis by the aitrendblend editorial team  ·  Robotics and autonomous systems  ·  Reading time about 15 minutes Soft Robotics Octopus Inspired Distributed Sensing Underwater Grasping Tactile Suction Cups Peripheral Control A soft conical arm feels an object with ten sensing suction cups and wraps around it, no camera and no central brain telling each cup

An Octopus Inspired Soft Arm That Grasps By Feel Read More »

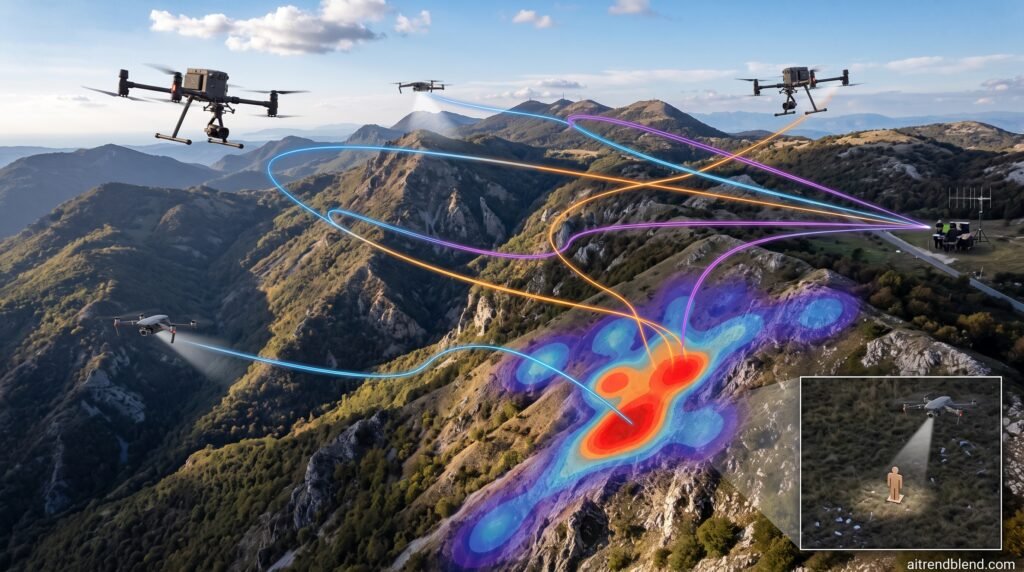
How Croatian Researchers Taught UAV Swarms To Search Hills Like Water Finds Level

How Croatian Researchers Taught UAV Swarms To Search Hills Like Water Finds Level

Analysis by the aitrendblend editorial team. Source paper published in IEEE Transactions on Robotics, volume 42, 2026. Field validated on Mount Učka, Croatia. Ergodic Control Model Predictive Control Search And Rescue Multi Robot Systems HEDAC UAV trajectories converging on high probability zones while altitude adapts to underlying terrain. Illustration adapted from the framework described in

How Croatian Researchers Taught UAV Swarms To Search Hills Like Water Finds Level Read More »